|
|
 |
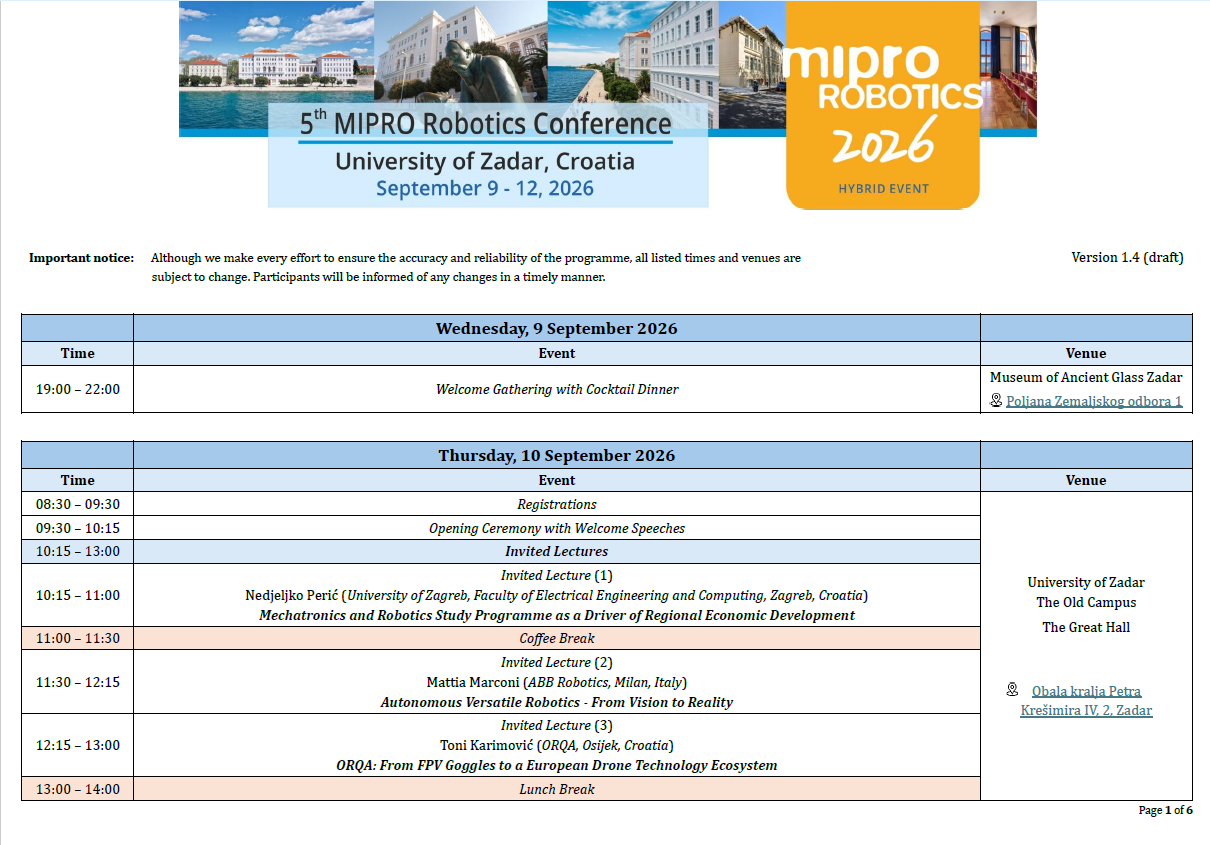
Hibridni događaj
|
17:10 - 18:50 Drones for Safety and Purpose
Chair: TBA |
M. Jelić (University of Applied Sciences “Marko Marulić” in Knin, Knin, Croatia), V. Uroš (Faculty of Organization and Informatics, University of Zagreb, Varaždin, Croatia)
Drones in Ecology and Environmental Monitoring: Bibliometric State of the Art and Growth Forecasts to 2035 
Unmanned aerial vehicles (UAVs) have moved from a niche research tool to a standard sensing platform in ecology and environmental protection, yet the pace and the likely saturation of this adoption have not been quantified. We compiled annual counts of peer-reviewed articles combining UAV terms with ecological and environmental terms from the open bibliographic index OpenAlex for 2005 to 2025 (20,344 articles), together with three normalising denominators and six application sub-domains, and fitted four growth models (exponential, logistic, Gompertz and Bass diffusion) by Poisson deviance in a toolbox-free MATLAB pipeline. Models were compared with a quasi-likelihood information criterion, validated by rolling-origin backtesting and bootstrapped for forecast intervals. Output grew at 29.3 percent per year (28 articles in 2005, 4,747 in 2025), with a structural break in 2010. Absolute output shows no saturation yet: the model average predicts 8,466 articles in 2028 [90 percent interval 5,996–10,303]. Over ten years the models diverge, and the long-horizon count forecast consistent with the share analysis is the average of the three saturating models: 17,058 articles in 2035 [4,056–42,253]. The share of environmental literature that uses UAVs, however, is clearly saturating: a logistic model with weight 0.999 gives a plateau of 13.3 articles per 1,000 (13.0 without the partly artefactual 2025 observation), of which 85 percent was reached in 2025. Growth is shifting from mature applications (wildlife counting) to sub-domains with open sensing problems (forest health, gas emissions, wildfire). Implications for UAV design and autonomy are discussed.
|
J. Klasinc (Croatian Institute for Public Administration, Zagreb, Croatia)
AI-Assisted Detection of Building Stratigraphic Indicators: a Conceptual UAV to GeoBIM Framework
This conceptual paper proposes an integrated framework that combines Unmanned Aerial Vehicle (UAV) photogrammetry, artificial intelligence (AI)-based computer vision, and Scan-to-BIM methodologies to identify and semantically distinguish different construction phases within existing buildings. Rather than focusing solely on geometric reconstruction, the proposed approach aims to detect probable boundaries between original structures and subsequent additions by analyzing roof morphology, façade characteristics, building materials, volumetric changes, and other visual and geometric features extracted from high-resolution aerial imagery and three-dimensional point clouds. The identified construction phases are incorporated into a georeferenced BIM model enriched with semantic attributes describing structural chronology, building components, and potential seismic vulnerability. The prospective resulting GeoBIM model provides a digital representation that could support post-earthquake reconstruction, infrastructure management, and evidence-based urban planning. Furthermore, the paper explores the conceptual integration of these enriched BIM datasets with Croatia's digital planning and permitting platforms (e-Plan and e-Dozvola), enabling improved interoperability between geospatial data, building information, and administrative processes, using Zagreb as a case study.
|
N. Martinović, D. Delija, G. Sirovatka, M. Žagar (Zagreb University of Applied Sciences, Zagreb, Croatia)
Python-Based Forensic Analysis of UAV Flight Logs for Tactical Decision Support
Unmanned aerial vehicles (UAVs) record telemetry of interest both to digital forensic examiners and to analysts working under operational time pressure. This paper reports a case study in the forensic triage of UAV flight logs. Nine encrypted DJI Fly flight records from a DJI Mini 2 SE, comprising 40,476 telemetry rows, were taken from the controlling mobile device, decrypted to CSV with proprietary third-party tools, and processed with a Python program that groups flights by launch proximity and reports, per sortie, the maximum range from launch and the bearing to the most distant fix. The substantive results are diagnostic. Taking the first valid GNSS fix as the launch point fails in one of the nine logs, where that fix is a receiver acquisition transient lying 107 m from the solution reported 1.2 s later; the error propagates into the reported reach of that sortie, into the export tool's own distance channel, and into the grouping, where at a threshold of 500 m it makes group membership depend on the order in which files are read, yielding three different partitions across 2002 input orders. Rejecting fixes below a documented GNSS signal-quality level removes the failure and makes the partition invariant over thresholds from 25 m to 500 m and over every order tested, in agreement with DBSCAN. With that correction, launch estimates from the one site used on more than one occasion agree to 10.4 m across an interval of 66 days. Only one of the three operating areas recovered is used on separate occasions, so these logs support a claim about launch-point estimation and grouping stability, and do not support the pattern-of-life reading that such outputs invite.
|
A. Vafayev, M. Kerimkul (META Univeristy, Almaty, Kazakhstan)
Safety-Constrained Dynamic Leader Election for GNSS-Denied UAV Swarms via Masked Reinforcement Learning
This paper addresses the problem of coordinating a swarm of small UAVs in GNSS-denied forest environments. Centralized control architectures exhibit low fault tolerance in such environments, while existing dynamic leader election methods based on fixed thresholds fail to adequately adapt to non-stationary operating conditions. We propose a decentralized leader election algorithm implemented as a multi-agent neural network trained using Proximal Policy Optimization (PPO) with invalid-action masking. The agent’s state space includes eight features for each UAV: residual battery charge, RSSI signal dynamics, available onboard computational resources, integrated sensor data quality, agent reputation index, topological centrality in the swarm graph, LiDAR data quality, and accumulated time holding the leader status. The action mask encodes an energy-and-link failure condition, acting as a hard safety constraint on which UAV may lead rather than as a learned preference; it is decoupled from the exported policy graph and applied in the ROS 2 node. The frozen policy is transferred end-to-end to a Gazebo / ROS 2 / PX4 SITL stack with inter-agent communication over the Micro XRCE-DDS protocol, where GNSS denial is modelled at the criteria layer. In a paired evaluation against seven baselines the learned policy is competitive with the strongest heuristic — marginally below it in the nominal regime — while dominating the other six. The safety benefit is attributable to the action mask and is transferable: applying the same mask to the strongest heuristic reproduces the identical bounded handover (E ≈ 0.19), whereas without the mask the learned policy relinquishes leadership only at E ≈ 0 (5/5 versus 0/5 on the energy emergency). The three vehicles agree on the leader in every scored round without any voting protocol.
|
I. Jajić, B. Jaković, T. Ćurlin (Faculty of Economics and Business, Zagreb, Croatia)
Emerging Business and Logistics Perspectives on Drone Delivery: A Bibliometric and Keyword CoOccurrence Analysis of 2025 and Early 2026 Research
Drone delivery is no longer seen merely as a technology-driven solution to the last-mile problem but rather as a business innovation in itself. The paper authors seek to explore the bibliometric framework of drone delivery literature released in 2025 and early 2026. For this reason, 4,420 entries were identified using the topic search of the Web of Science Core Collection database. Following the filtering process through the database, there were 233 items left to be manually screened through the titles and abstracts, and 122 of them qualified after excluding 111 irrelevant ones. VOSviewer was employed with all keywords, full counting, a cutoff value of five documents, and a custom thesaurus. The final network comprised 27 keywords, 202 links, and four thematic clusters - operational routing and truck-drone delivery; drone delivery adoption and service applications; UAV delivery network design under cost and uncertainty; and logistics optimization and location-routing. The findings show that the screened corpus retains a strong optimization core while also addressing consumer adoption, e-commerce and healthcare applications, cost, and uncertainty.
|
|
The detailed 4-day programme can be dowloaded HERE.
Basic information:
Chairs:
Marko Valčić (Croatia), Dean Martinović (Croatia), Ive Botunac (Croatia), Martina Grubor (Croatia)
Steering Committee:
Tadej Bajd (Slovenia), Ante Bakić (Croatia), Ricardo Branco (Portugal), Stjepan Bogdan (Croatia), Mario Čelan (Croatia), Bojan Jerbić (Croatia), Ervin Kamenar (Croatia), Zlatko Katalenić (Slovenia), Igor Kotenko (Russia), Zdenko Kovačić (Croatia), Jonatan Lerga (Croatia), Gyula Mester (Hungary), Nikola Mišković (Croatia), Danica Kragić Jensfelt (Sweden), Duc Truong Pham (UK), Vincenzo Piuri (Italy), Ioan Sacala (Romania), Bruno Siciliano (Italy), Karolj Skala (Croatia), Saša Sladić (Austria), Tadej Slapnik (Slovenia), Uroš Janez Stanič (Slovenia), Marko Šarlija (Croatia), Zorislav Šojat (Croatia)
Local Organizing Committee:
Željka Tomasović (Croatia), Mate Barić (Croatia), Marijana Marjanović (Croatia), Mirjana Plečko (Croatia), Željko Goja (Croatia), Draško Stipić (Croatia), Marija Valčić (Croatia)
Registration / Fees:
|
REGISTRATION / FEES
|
Price in EUR
|
EARLY BIRD
Up to September 1, 2026 |
REGULAR
From September 2, 2026 |
| IEEE members |
315 |
360 |
| MIPRO members |
315 |
360 |
| Students (undergraduate and graduate), primary and secondary school teachers |
175 |
200 |
| Others |
350 |
400 |
The student discount doesn't apply to PhD students.
NOTE FOR AUTHORS: In order to have your paper published, it is required that you pay at least one registration fee for each paper. Authors of 2 or more papers are entitled to a 10% discount.
The registration fee is paid by the author participating in the conference. In the case of multiple co-authors, a 10% discount is granted on each subsequent registration fee.
Contact:
Marko Valčić
University of Zadar
Mihovila Pavlinovica 1
HR-23000 Zadar, Croatia
E-mail: mvalcic@unizd.hr
Accepted papers will be published in the ISSN registered conference proceedings. Papers presented at the conference will be submitted for inclusion in the IEEE Xplore Digital Library.
Location:
Zadar, one of the oldest cities on the Adriatic, blends ancient heritage with modern life. Its Roman forum, medieval churches, Venetian fortifications, and iconic Sea Organ attract visitors worldwide. Surrounded by islands and national parks, it offers stunning sunsets and rich cultural experiences.
With top hotels, gastronomy, and festivals, Zadar unites history, innovation, and Mediterranean charm. Today, it is also an emerging hub for congresses, technology, and sustainable development in Southeastern Europe.
For more details, please visit https://zadar.travel/.
|
|